Robotics & Autonomy On real roads since 2016.
Machines that sense, decide and act in the physical world: autonomous vehicles, robots and physical automation. It comes out of REKA’s applied R&D, starting with Malaysia’s first self-driving car on open roads, and it lives in Kinetik, REKA’s autonomy division.
We do not chase drive-anywhere. We engineer autonomy that runs and pays inside a known domain, on an open, auditable stack, with a person always one step away.
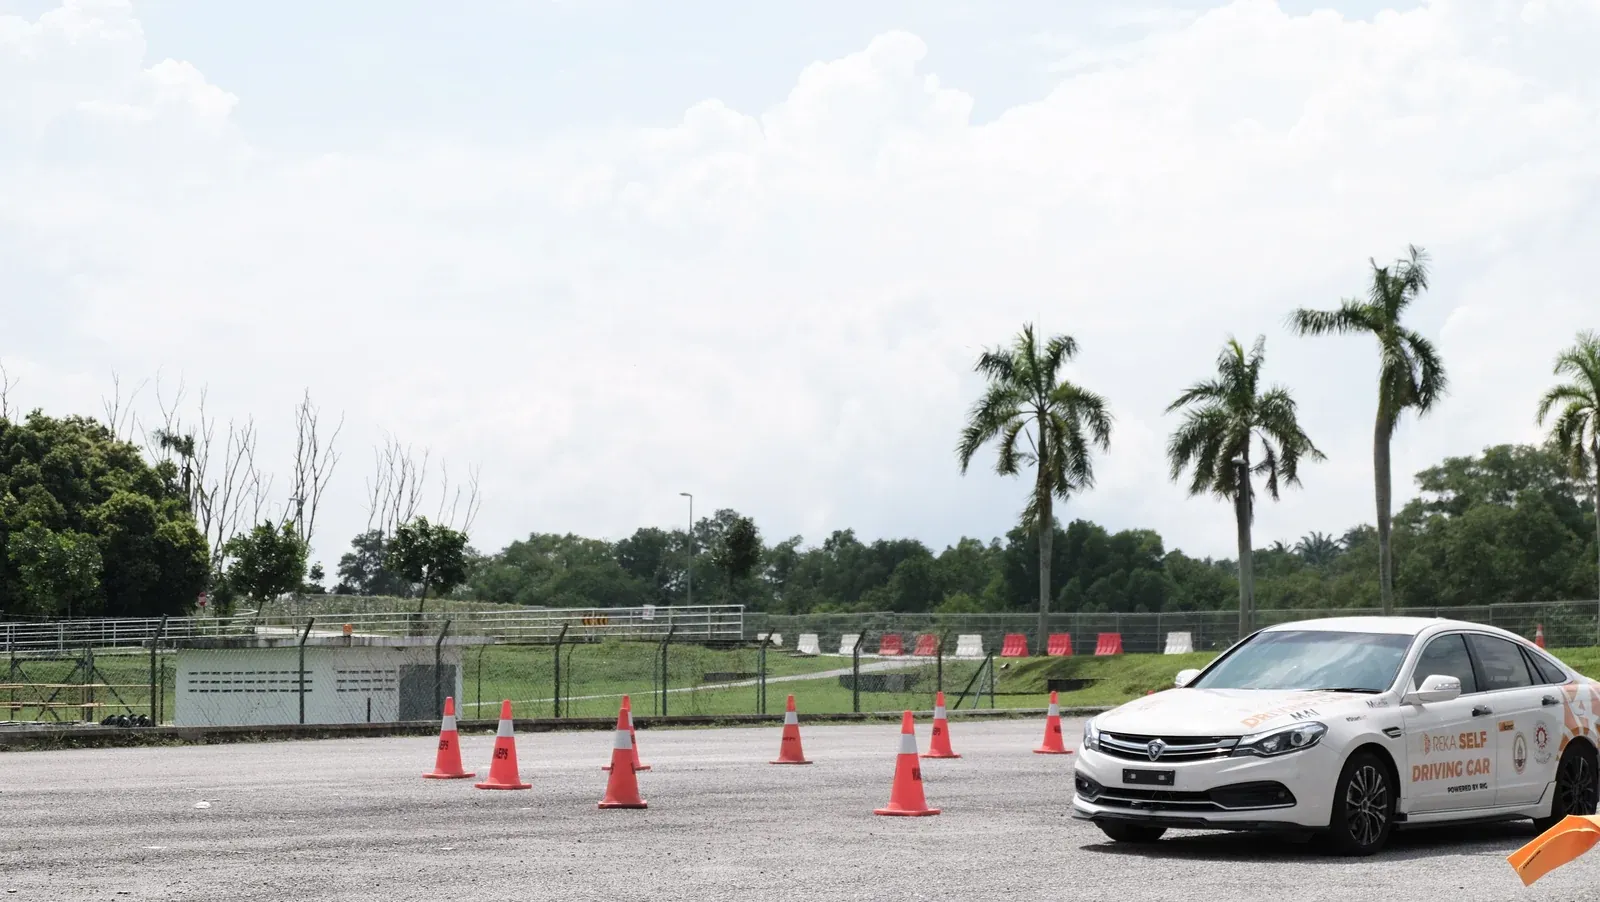
What we work on
Every part of a machine that drives itself, from the board it runs on to the person who takes over at the edge of its domain.
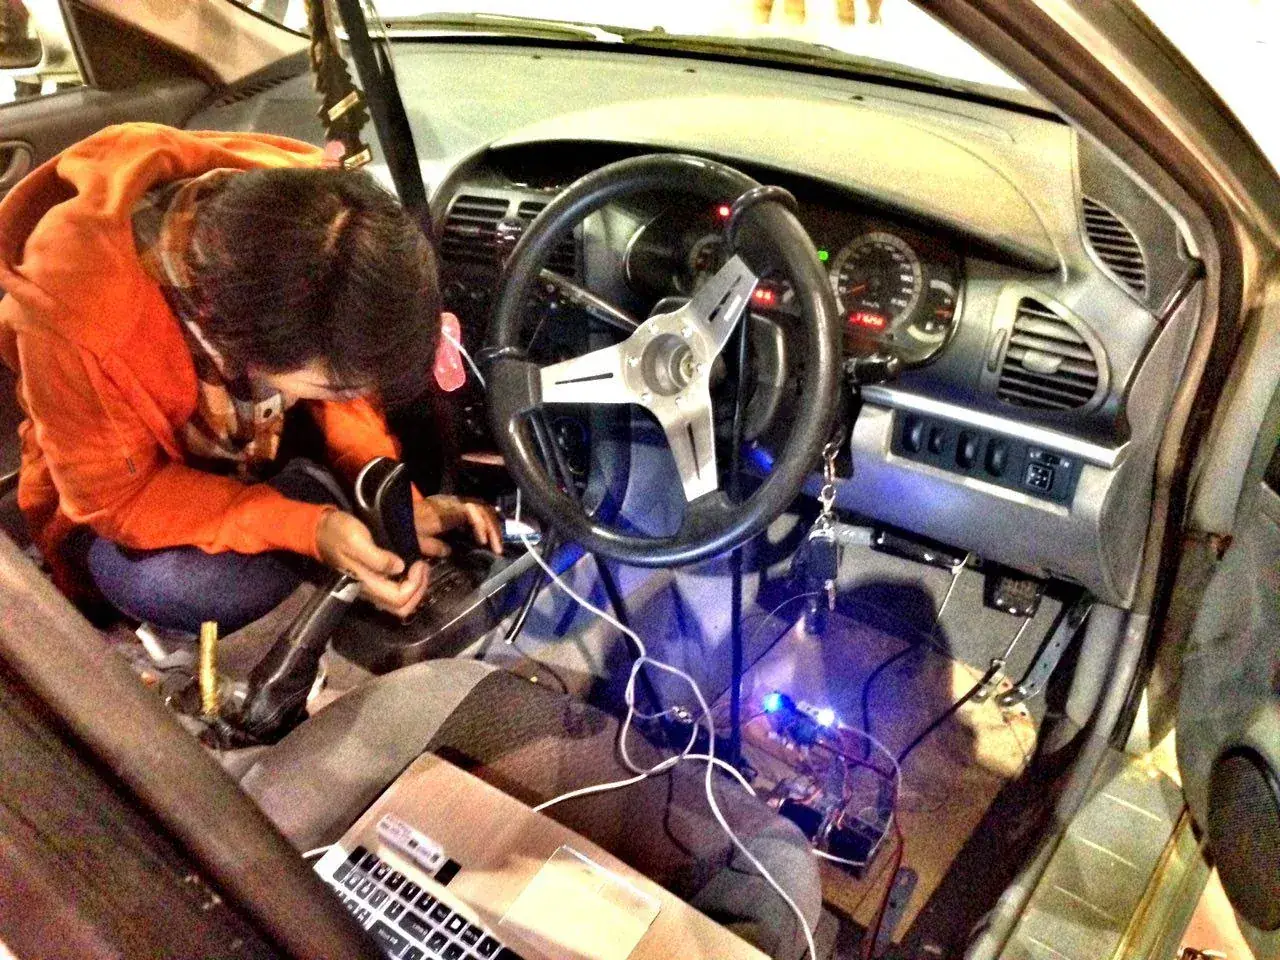 Autonomous vehicles on open roads
CRETA MK I, 2016: a retrofit kit for an ordinary car, a Proton Waja, with one webcam, and motors, servos and REKA’s own electronics, including its RIG board, on the wheel and pedals. It drove from Melaka to Kuala Lumpur on the PLUS Highway with no one in the driver’s seat.
The case study →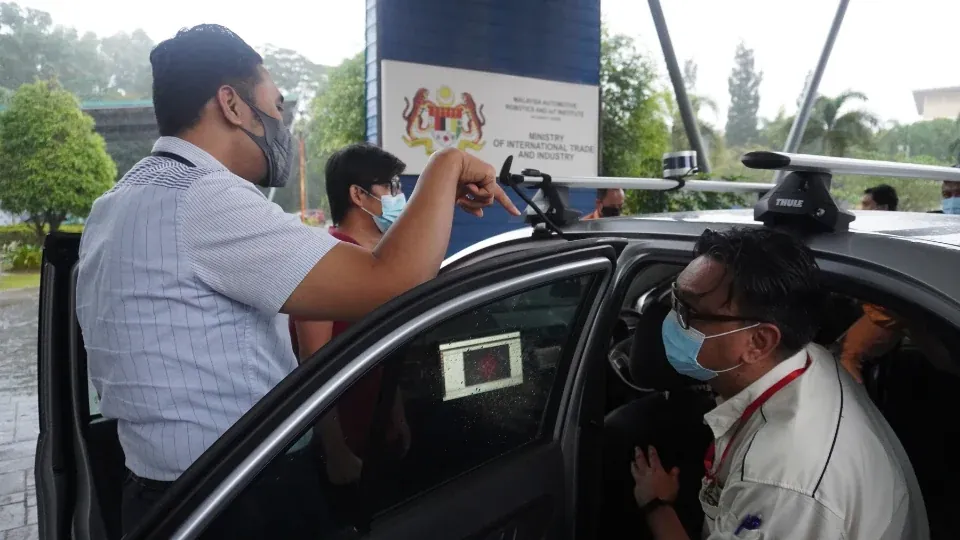 The open Autoware stack
We build on Autoware, so every layer can be opened, examined and replaced, and we tune it for the region’s roads, weather and traffic. On the stack since 2021, a member of the Autoware Foundation since 2024.
The full stack →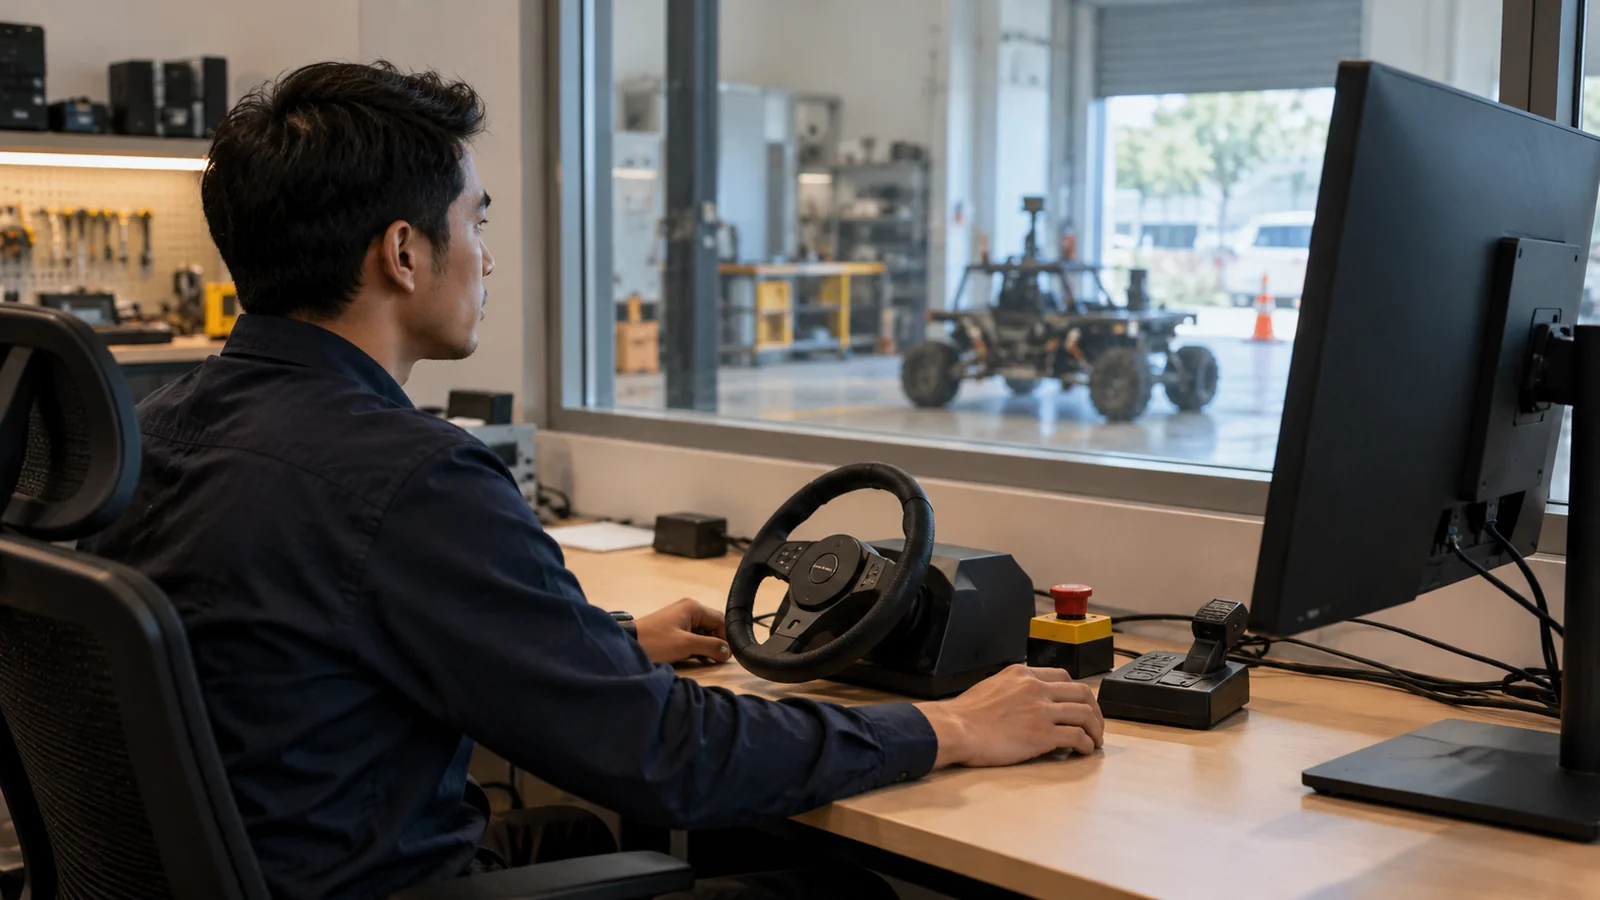 Teleoperation and remote operation
Teleoperation is a designed layer, not a failure mode. The machine hands over cleanly at the edge of its domain to a remote operator. Our 2022 MoU with Elmlab covers connectivity and teleoperation.
On remote operations →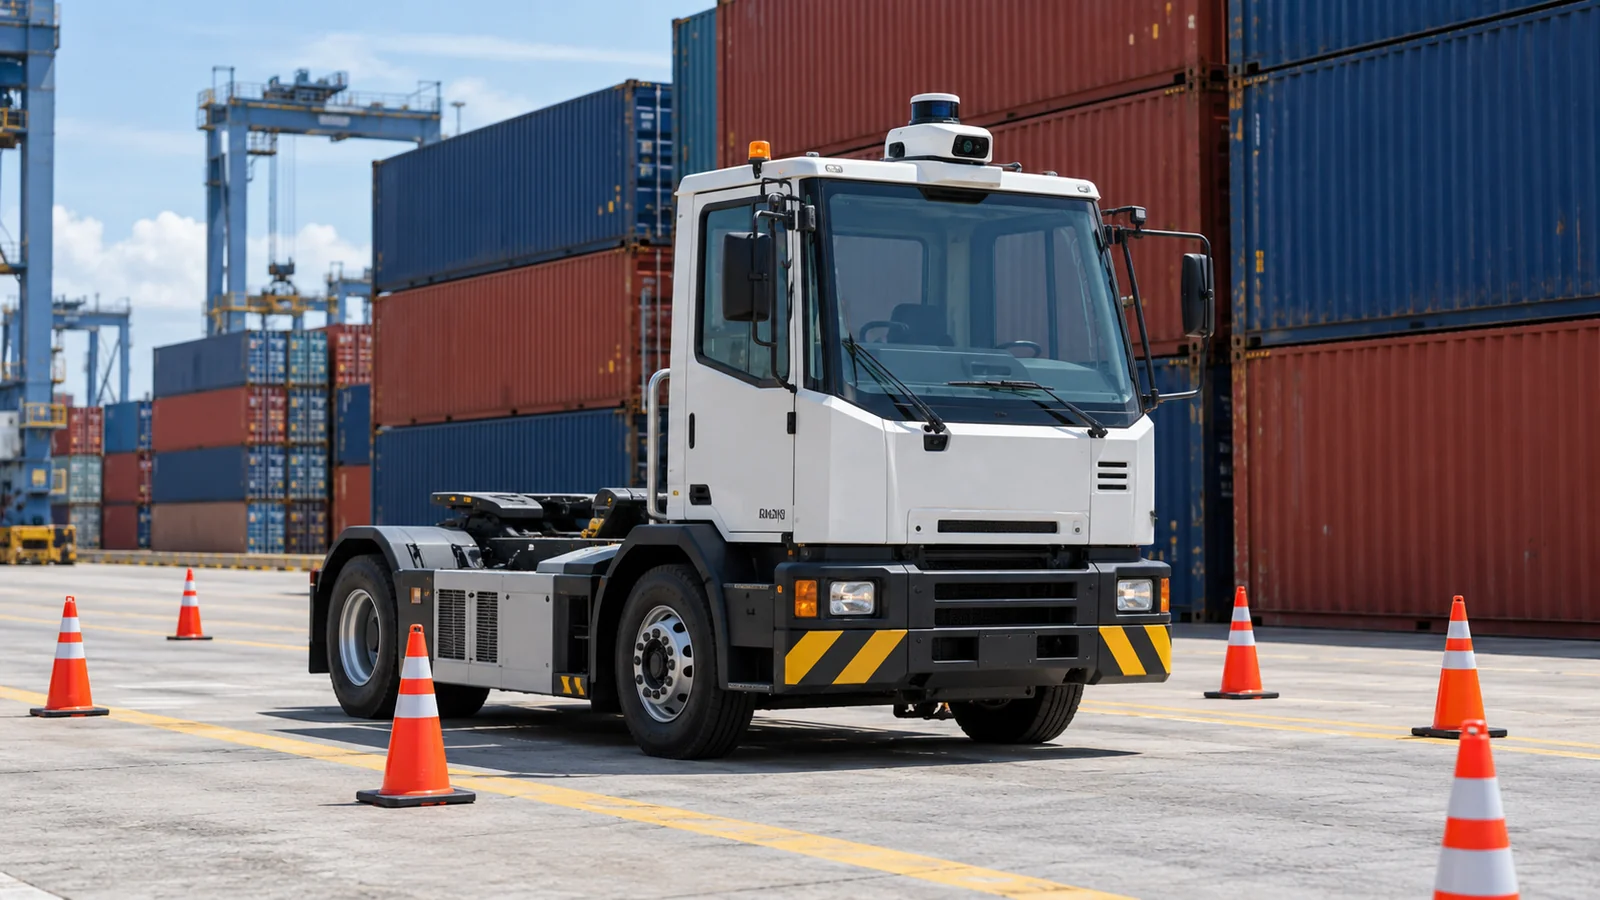 Autonomous machines in bounded domains
We start where autonomy already works and pays: yards, ports, farms and fixed routes. Prove it inside a boundary, then widen it. A machine that knows where it stops is one you can make a safety case for.
Domain first →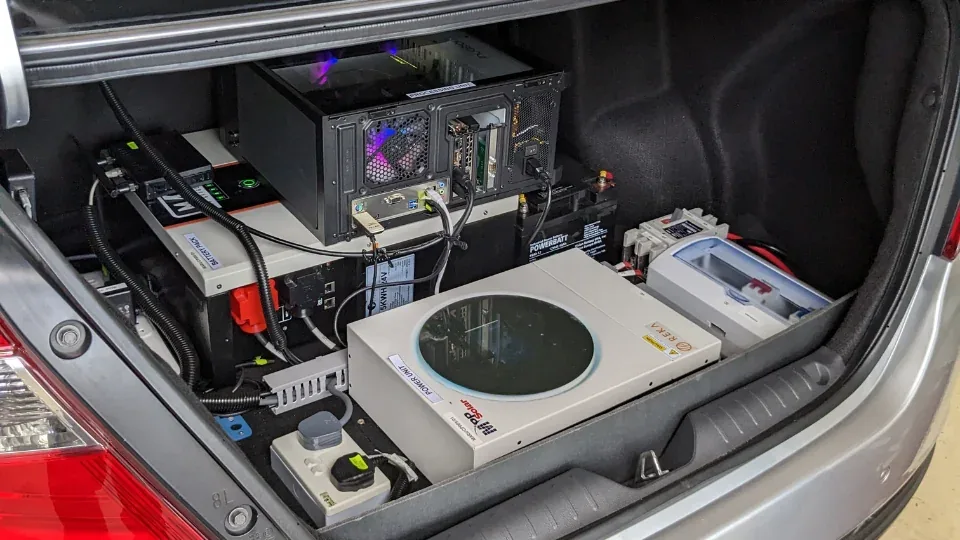 Fleets and telematics
Motion, telematics and fleet management built first for autonomous and remote-controlled vehicles, carries this work forward. It is a closed pilot at AntaraX, the product company created from REKA research.
Mobility & automotive → From the car to everything else
The sensors and edge computing built for the car became PLExyz. Its computer vision and AI inference were repurposed to read patterns in business data. Its telemetry and real-time systems became our automation work. Robotics and autonomy research stays with Kinetik.
Sensing & Data →Not a roadmap. A record.
REKA has been building autonomous technology in Malaysia since 2016, before most programmes here existed.
On the record
- 2016Malaysia’s first self-driving car, and the first in Southeast Asia on public highways: Melaka to Kuala Lumpur
- 2017MK II and MK III, with MIDA, NanoMalaysia and MARA; public rides at the Malaysia Autoshow with MARii; shown at NICE Expo with MARA and MARA Corp
- 2021We start building on the open-source Autoware stack
- 2022An MoU with Elmlab on connectivity and teleoperation
- 2023An autonomous test bed at the Malaysia Autoshow, after testing on a Cyberjaya route
- 2024REKA joins the Autoware Foundation as a member
ReadoutMelaka to Kuala Lumpur on the PLUS Highway, 2016. Hover or tap a place to read it.
A Proton Waja with one webcam and REKA’s own electronics. Then a Proton Inspira courtesy of MIDA, and two Proton Perdanas from NanoMalaysia and MARA, with LiDAR, radar and more cameras.
Read the case study
SETHAutonomy is only trustworthy if it knows where it stops.
ReadoutHover or tap a zone to read what happens there.
The approach, the seven-layer stack, the driving loop and the specifications, with an honest view of what ships now and what is still the bet.
Visit the Lab Illustrative detail · not a project photoMobility & automotive
Autonomous systems and connected vehicles, and what the press wrote in 2016 and 2017.
See the industry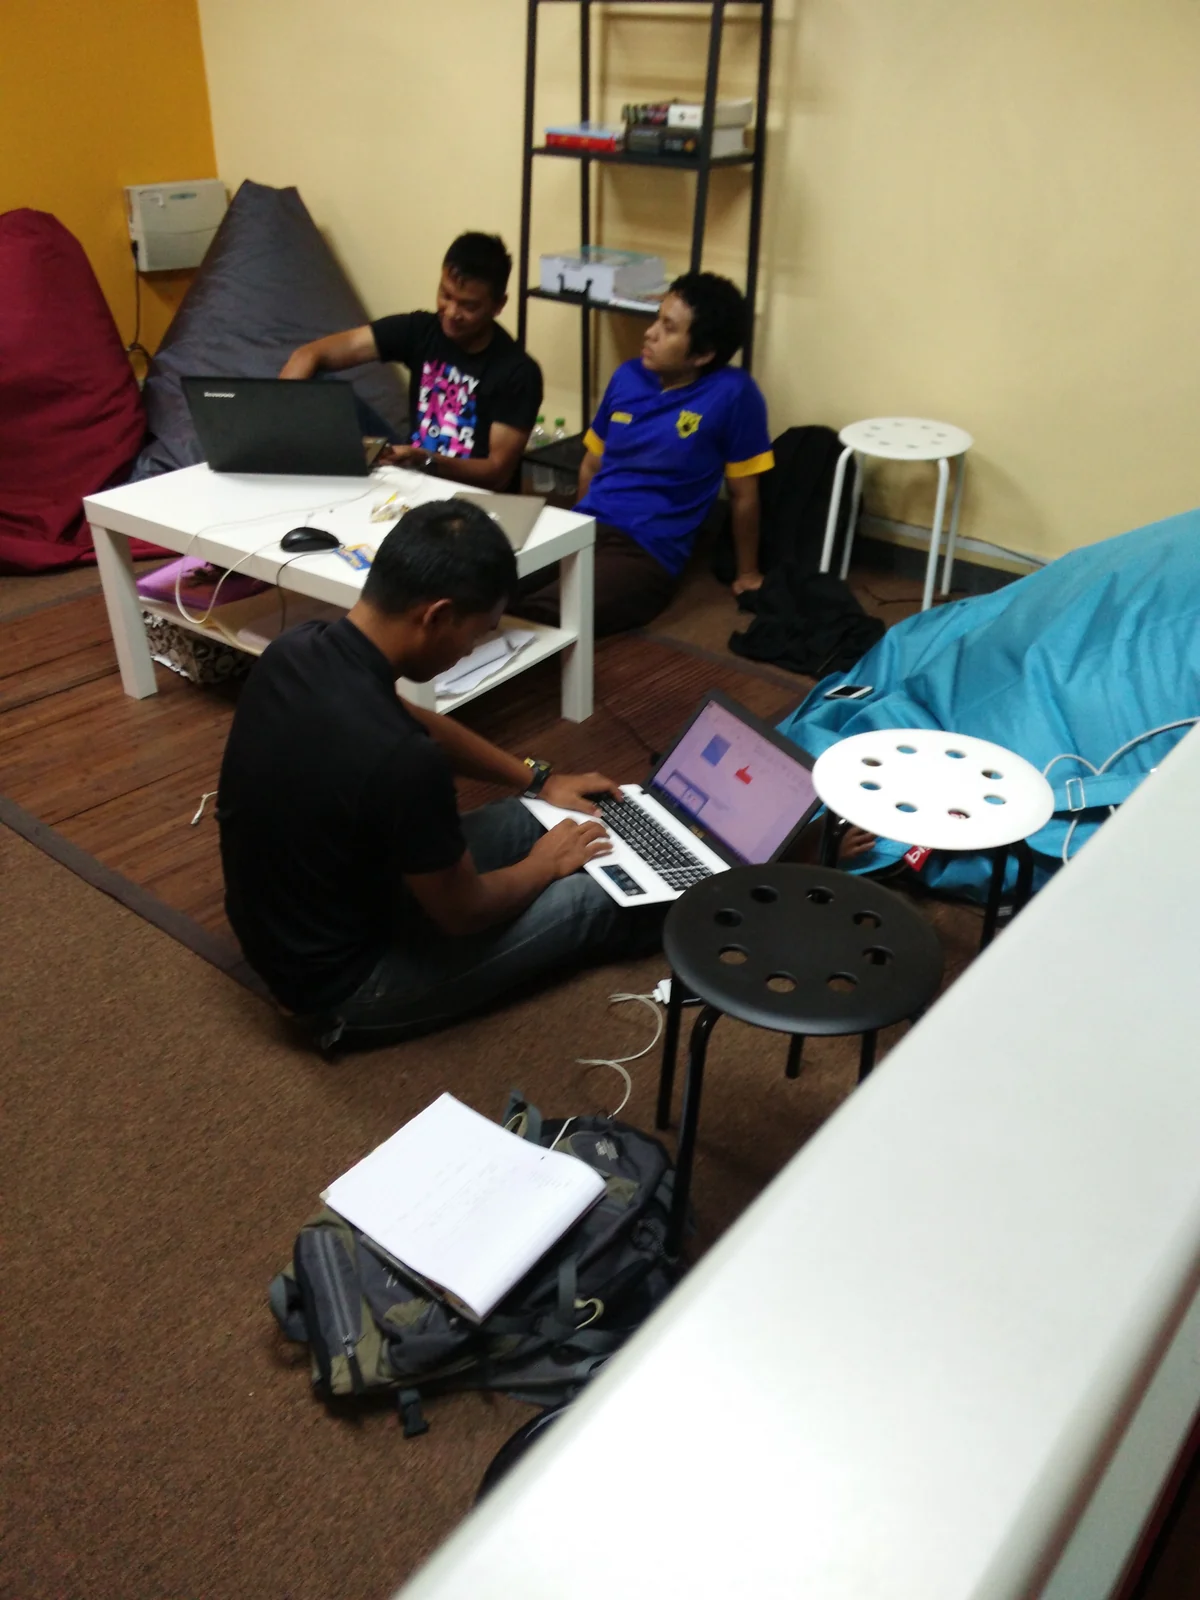 That car built everything that came after
From a design studio in 2013 to a car that drove itself three years later, and what followed.
Read our story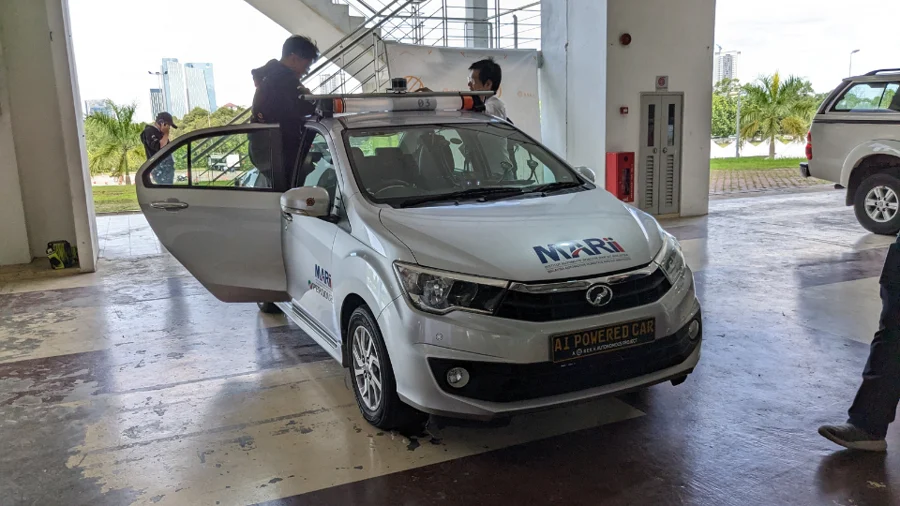 MARii and REKA show autonomous vehicle technology at the Malaysia Autoshow 2023Read the article
We have worked with the Autoware Foundation and TIER IV on autonomous systems, and with MARii, Elmlab, MIDA, NanoMalaysia and MARA on vehicles in Malaysia. Who we work with →
- Autoware
- TIER IV
- MARii
- Elmlab
- NanoMalaysia
How to work with us on it
Robotics and autonomy are what we work on. These are the three ways in.
Automate the operation around the machine, and with Managed AI we keep it running for you: hosted, monitored and improved, with a remote operator in the loop where judgement matters.
Service Consulting & AdvisoryAn honest view of where advanced autonomy applies to your site now, which domain to start in, and what has to be true before a machine runs on its own.
Service Custom Build & R&DRobotic and autonomous machines designed for your environment and tested in it, from sensors and edge hardware to the stack, as a build or a longer R&D partnership.
Service