Autonomous Driving
Civilisation spent a hundred years building itself around fossil fuel. Autonomy is how we start building it for something else.
We do not chase drive-anywhere. We engineer autonomy that runs and pays inside a known operating domain, on an open, auditable stack, with a human always one step away through teleoperation. Then we widen it.
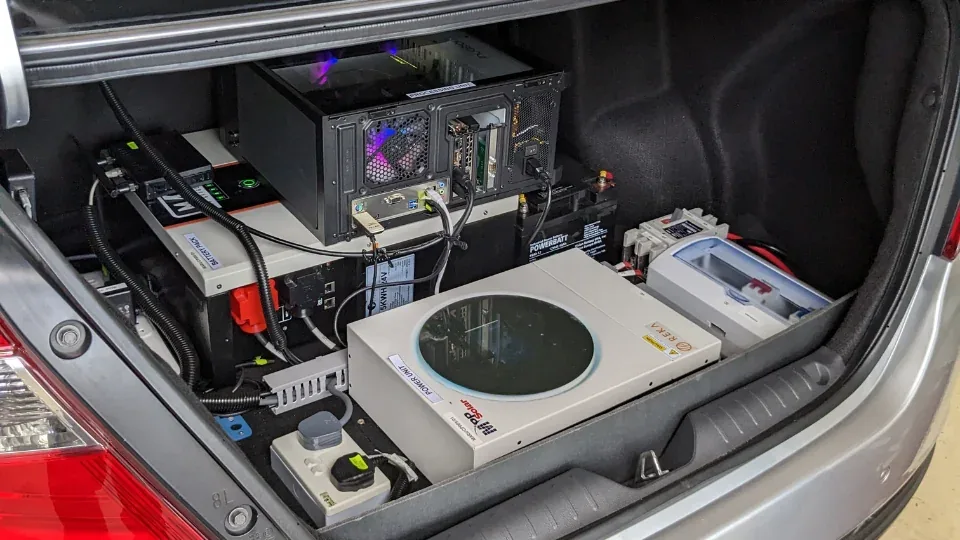
- First on public highways
- 2016Malaysia’s first self-driving car, and Southeast Asia’s first on public highways
- Sensors fused
- 3+LiDAR, radar, camera, plus GNSS/IMU
- Control loop
- 10–100 HzPlanning to control, on automotive compute
- Localisation
- cm-levelWith HD maps, even where GPS is weak
Domain first. Then wider.
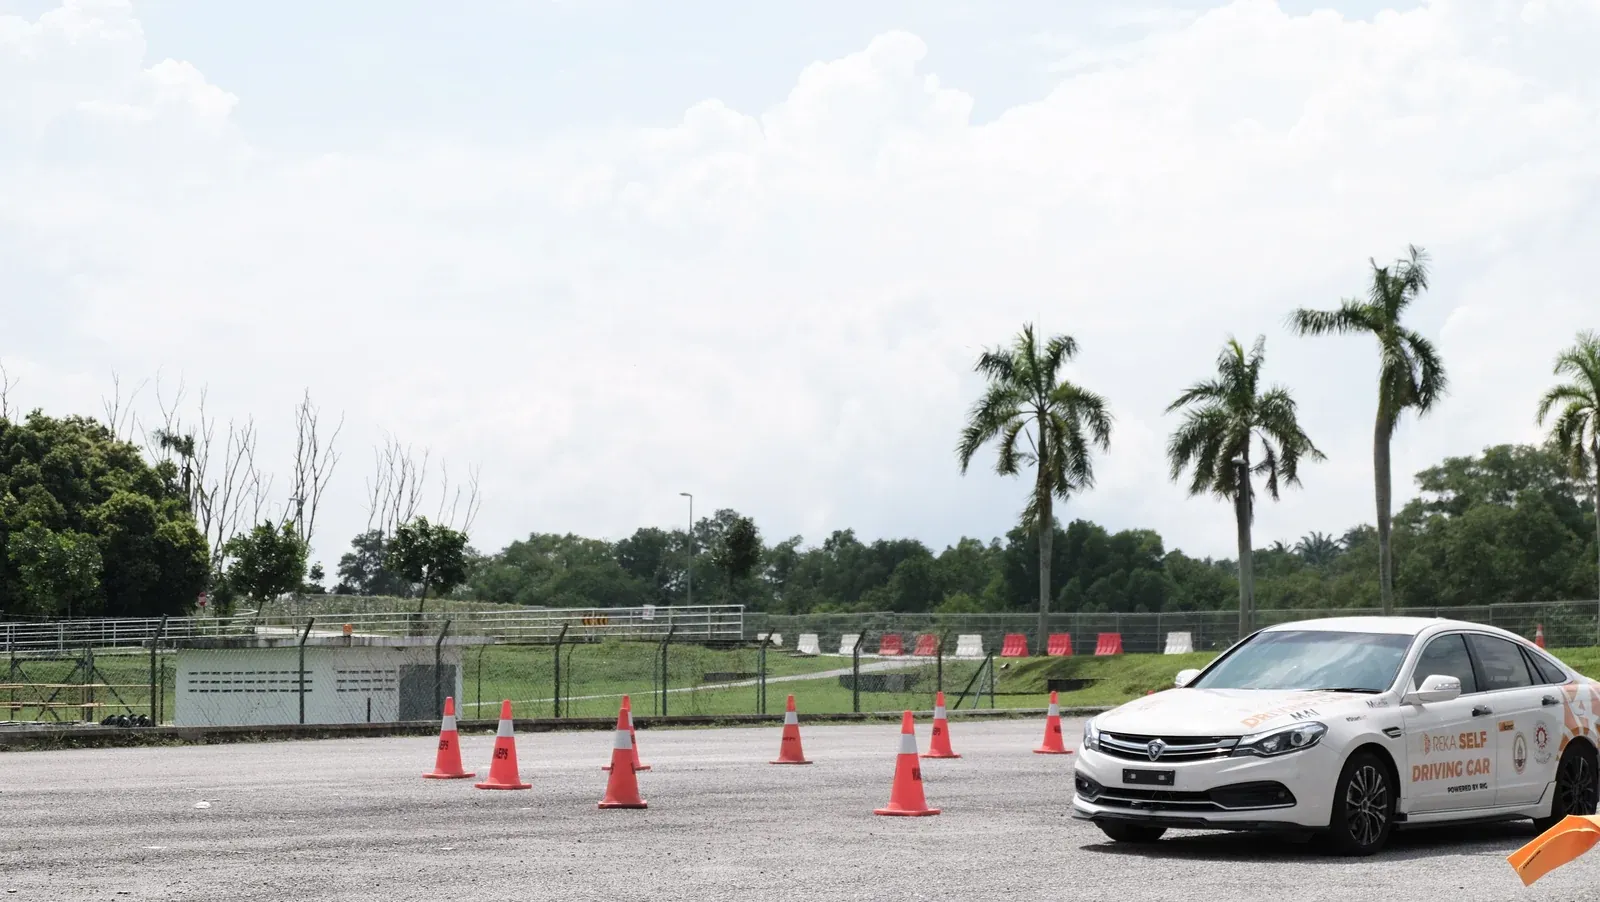
Domain first
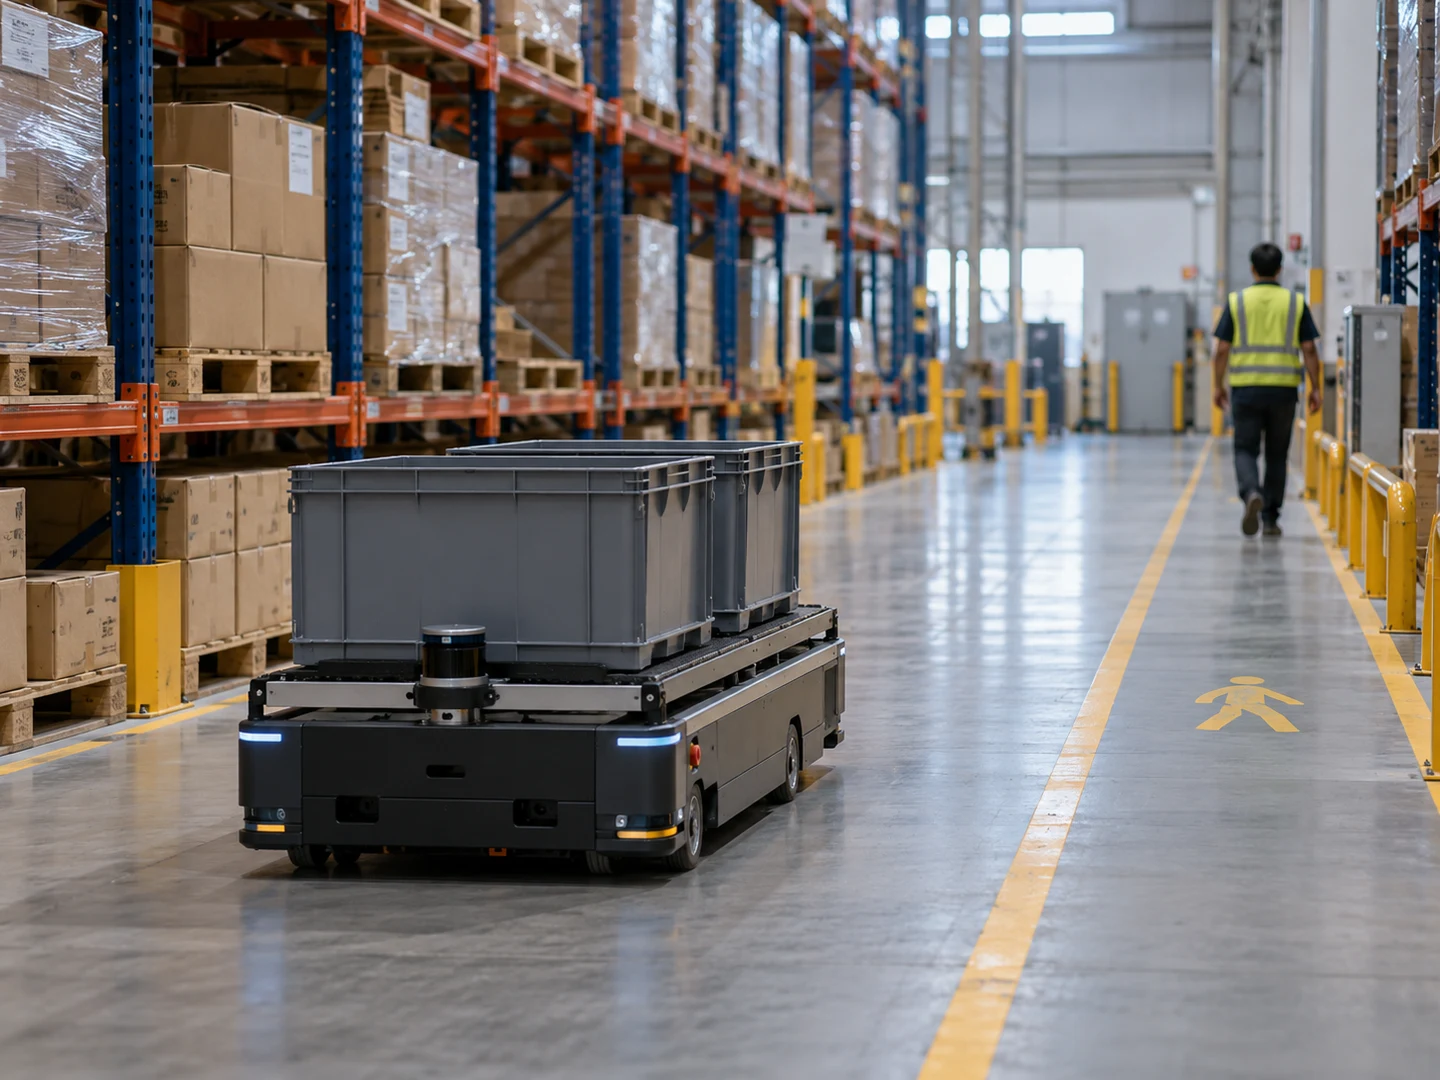
We bound the world the machine operates in. Not waiting for Level 5, we start where autonomy already works and pays: yards, ports, farms, fixed routes. Prove it inside a boundary, then widen it.
Open stack
We build on Autoware, auditable and inspectable, not a sealed black box. When a regulator, an insurer, or an operator asks how a decision was made, “the model decided” is not an answer. Every layer of our stack can be opened, examined, and replaced.
Human in the loop
Teleoperation is a designed layer, not a failure mode. The machine hands over cleanly at the edge of its domain. A person steps in, the situation is studied, the domain widens. A human is always one step away.
A decade in the field
We put Malaysia’s first self-driving car on the road in 2016, the first in Southeast Asia on public highways, before most of the region had a serious programme. That head start is the shape of the real problem understood from the inside, on our own roads, in our own conditions.
Widen the domain, watch the difficulty explode.
Every step from a fenced yard toward “anywhere, any weather, any time” multiplies the rare edge cases a system must handle safely. Drag the slider. Illustrative: the point is not the exact numbers, it is the shape. Difficulty is not linear in ambition.
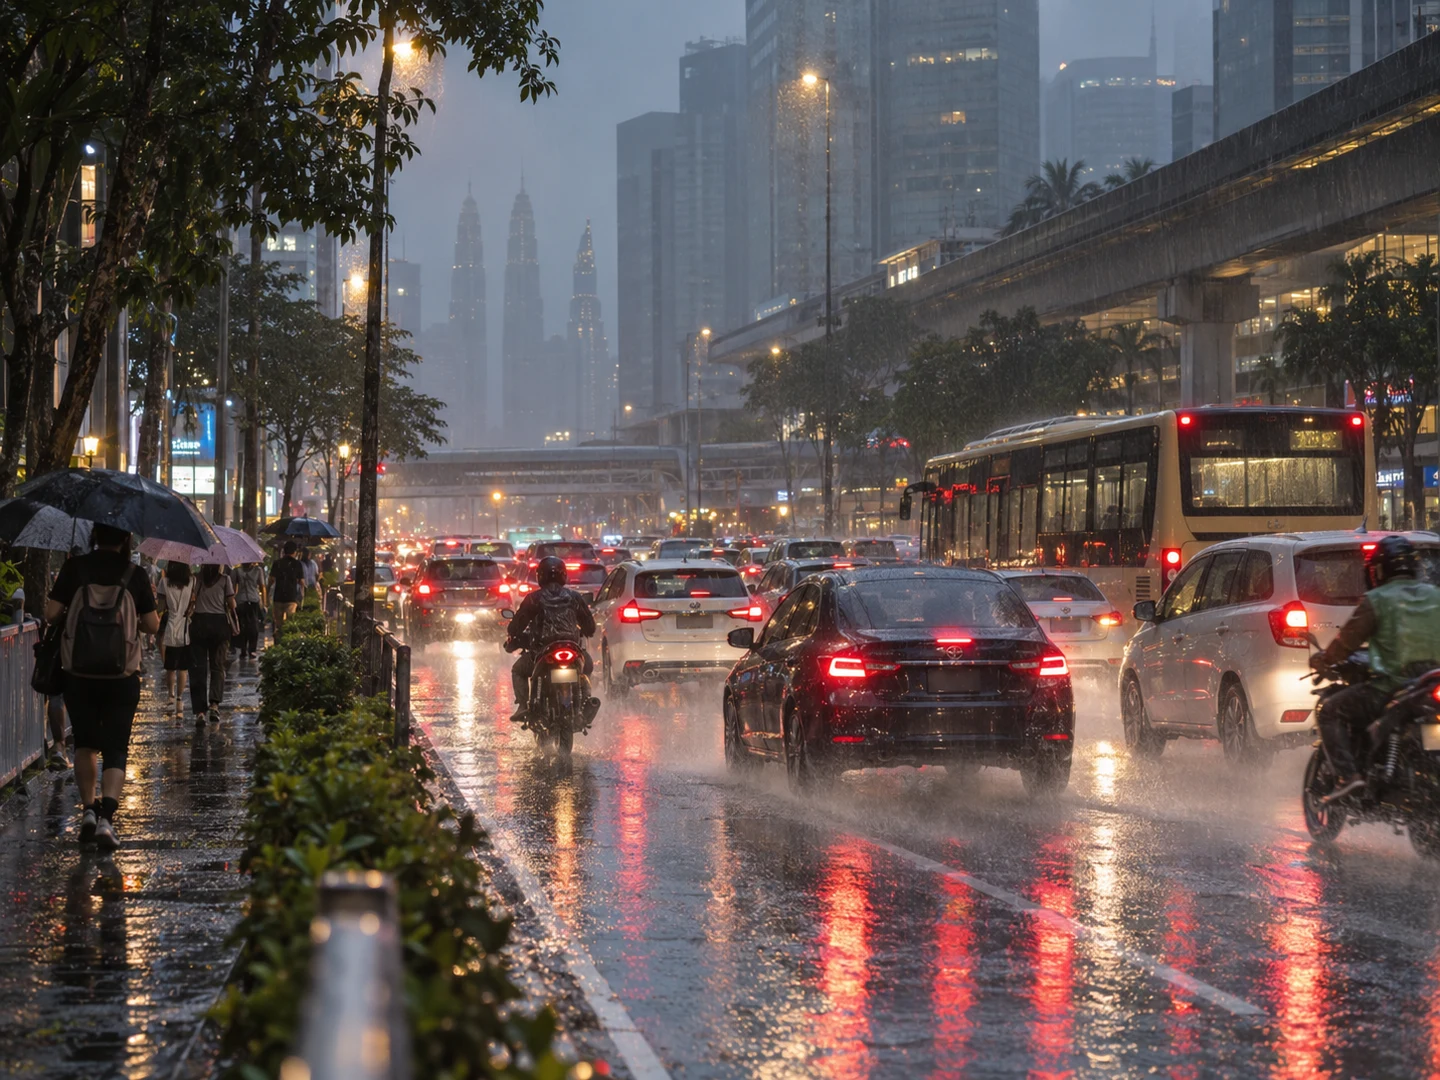
Teleoperation plus a tight ODD. Fenced, mapped, predictable. This is where autonomy already pays, and where we deploy first.
SETHAutonomy is only trustworthy if it knows where it stops.
ReadoutHover or tap a zone to read what happens there.
Knows where it stops.
Autonomy is only trustworthy if it knows where it stops. The boundary is a designed feature: it is what makes the safety case provable. Pick a zone.
The full autonomy stack.
A layered stack, from the sensors bolted to the vehicle up to the operations that watch over a fleet. Each layer is a module we can deploy, tune, or replace independently, so you adopt only what your use case needs.
It is built on open standards: as a member of the Autoware Foundation, we tune the open self-driving stack for the region’s roads, weather and traffic, and feed improvements back upstream. No vendor lock-in, full auditability for safety cases, and a stack your own engineers can inspect.
SETHEach layer is a module we can deploy, tune, or replace independently, so you adopt only what your use case needs.
ReadoutHover or tap a layer to read what it does.
The layers as a table
| Layer | Name | What it does | Typical |
|---|---|---|---|
| L1 | Operations, tele-ops & safety | Fleet monitoring, remote takeover, ODD enforcement and safety oversight. | fleet · teleoperation · safety case |
| L2 | Control | Trajectory following and drive-by-wire commands, around 50 to 100 Hz. | MPC · PID · DBW |
| L3 | Planning | Behaviour and motion planning in real traffic, around 10 Hz. | behaviour · motion · lattice / OMPL |
| L4 | Prediction | Multi-agent trajectory forecasting for vehicles, riders, pedestrians. | intent · trajectory |
| L5 | Localisation & HD mapping | cm-level pose from NDT scan-matching and GNSS-INS against an HD map. | NDT · SLAM · GNSS/IMU · HD map |
| L6 | Perception & sensor fusion | Detection, tracking and segmentation from fused LiDAR, radar and camera. | 3D detection · tracking · fusion |
| L7 | Sensors & vehicle interface | LiDAR, radar, cameras, GNSS/IMU and the drive-by-wire interface. | LiDAR · radar · camera · CAN / DBW |
Sense, decide, act, every cycle.
The driving loop runs continuously on the vehicle. Each stage feeds the next, then the world is sensed again, dozens of times a second: planning around 10 Hz, control around 50 to 100 Hz, depending on platform and ODD.
| Sense | Synchronised LiDAR, radar, camera, GNSS/IMU streams, time-stamped on ROS 2. |
| Perceive | Objects, lanes and free space from fused sensors. |
| Localise | cm-level pose on the HD map via NDT + GNSS-INS. |
| Predict | Where every nearby agent is likely to go next. |
| Plan | A safe, comfortable trajectory through the scene. |
| Act | Steering, throttle, brake via drive-by-wire. |
Not a roadmap. A record.
REKA has been building autonomous technology in Malaysia and the region since 2016, before most programmes here existed. This work now lives in REKA’s Kinetik division. The full story is in the self-driving car case study.
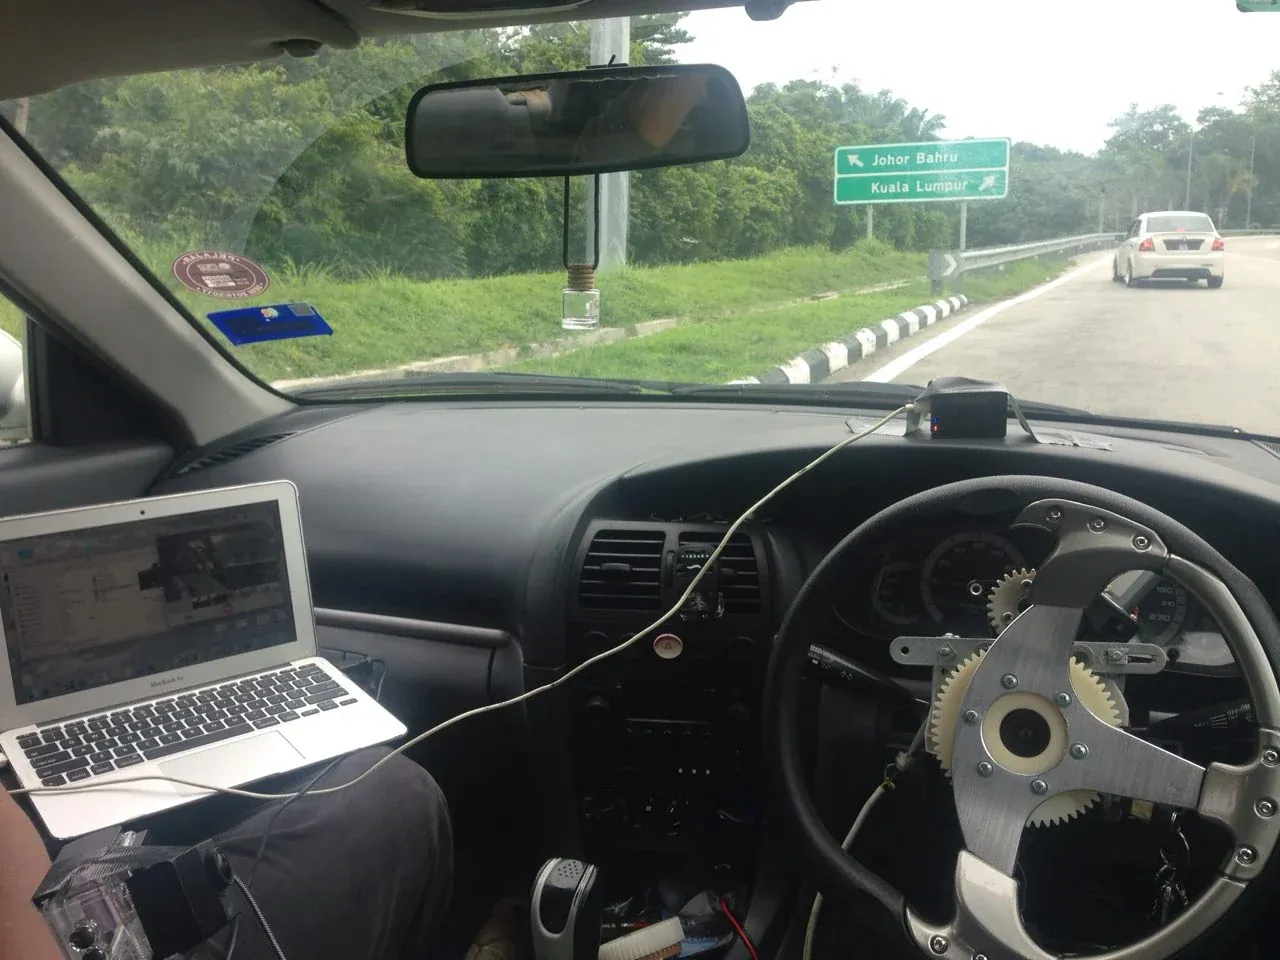
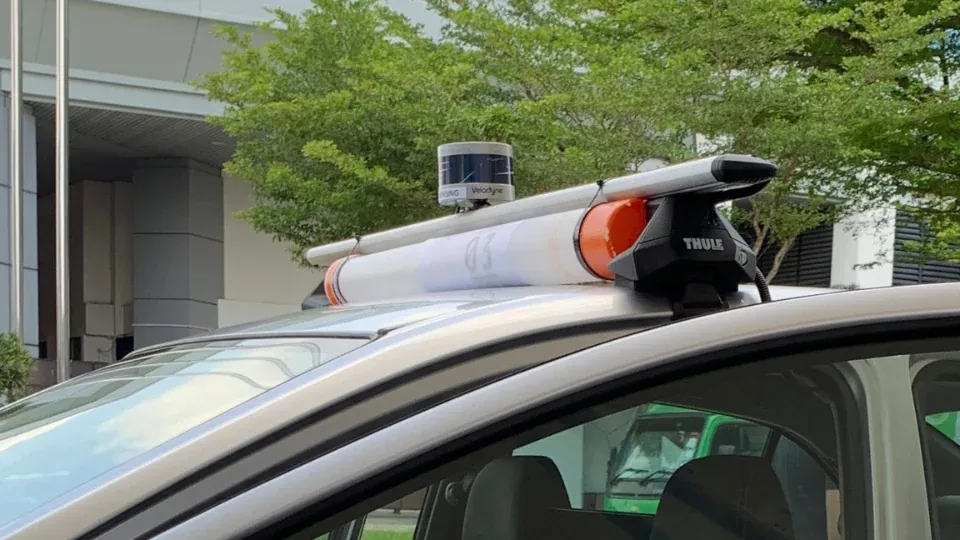
- 2016
Malaysia’s first self-driving car
CRETA MK I, a Proton Waja, drove from Melaka to Kuala Lumpur with no one in the driver’s seat: the first self-driving car in Southeast Asia on public highways.
- 2017
MK II and MK III, and NICE Expo
A Proton Inspira courtesy of MIDA, then two Proton Perdanas from NanoMalaysia and MARA, with LiDAR, radar and more cameras. Shown at NICE Expo, in space MARA and MARA Corp secured, where Malaysia’s Science Minister rode in the car.
- 2018
Autonomous systems for a Singapore port
An engagement on autonomous systems for port operations in Singapore.
- 2023
A test bed with MARii
Test runs on a dedicated route in Cyberjaya, then shown with MARii at the Malaysia Autoshow.
- 2024
Autoware Foundation member
Joined the Autoware Foundation as a member, after building on the open-source Autoware stack since 2021.
Bounded domains
Autonomous machines in warehouses, yards, farms and fixed routes, paying for themselves today. Single sites. Single domains. Already running.
Coordinated fleets
Multiple machines running as one operation over secure networks, with teleoperation covering edge cases. The proven domain, now at fleet scale.
The domain widens
As hardware, maps and regulation mature, the proven boundary expands. The organisations inside it first move first. We are getting clients ready.
Milestones, with sources.
The short version of the record. Each line says where it comes from: a dated source you can open, or REKA’s own record, with the documents to follow.
- 2016Documented
CRETA MK I, a retrofit kit on a Proton Waja
One webcam, with motors, servos and REKA’s own electronics, including its RIG board, on the wheel and pedals. Driven from Melaka to Kuala Lumpur on the PLUS Highway by the end of the year, with no one in the driver’s seat. Bernama TV and Harian Metro covered it.
Source: the CRETA case study and REKA’s press archive
- 2017REKA’s record
CRETA MK II and MK III
MK II (mid-2017), a Proton Inspira courtesy of MIDA, with one puck LiDAR and two webcams. MK III (late 2017), two Proton Perdanas, a maroon one lent by NanoMalaysia Berhad and a white one from MARA, each with at least two puck LiDARs, two side radars and three cameras.
Source: the CRETA case study and REKA press release, 16 October 2017
- Oct 2017REKA’s record
NICE Expo 2017, with MARA and MARA Corp
CRETA on show in Bukit Jalil, with MARA.
- Nov 2017Documented
Public rides at the Malaysia Autoshow, with MARii
Visitors rode in the retrofitted car at the Malaysia Autoshow 2017.
- May 2018Documented
Most research moves to software; autonomy carries on
Regulation, infrastructure and investment, rather than the technology alone, were named as the things to address first.
Source: REKA press release, 2 May 2018
- Mar 2022Documented
MoU with Elmlab on autonomous-vehicle technology
Co-development covering connectivity and teleoperation.
Source: New Straits Times, March 2022
- May 2023Documented
An autonomous test bed at the Malaysia Autoshow, with MARii
Shown after test runs on a dedicated route in Cyberjaya.
Source: REKA article, 19 May 2023
- 2024Documented
Member of the Autoware Foundation
After building on the open-source Autoware stack since 2021.
Source: the Autoware Foundation’s announcement and REKA’s member profile
- 4 Jul 2024REKA’s record
A regional workshop on piloting self-driving cars in ASEAN
In Yogyakarta, the co-founder took part by invitation, as a Malaysian industry expert and panel discussant, in a workshop on a regulatory pilot space to facilitate cross-border digital data flow for self-driving cars in ASEAN. It was organised by PUSTRAL UGM with an Indonesian ministry.
Documented: a dated source you can open. REKA’s record: confirmed by REKA, with the documents to follow.
Specifications.
Exact sensor suite, compute and ODD are scoped per platform and use case.
- Core platform
- Autoware (Universe / Core) on ROS 2
- Perception sensors
- LiDAR (mechanical / solid-state), automotive radar, mono/stereo cameras, GNSS/IMU
- Localisation
- NDT scan-matching · GNSS-INS fusion · HD vector + point-cloud maps · cm-level
- Planning & control
- Behaviour + motion planning · MPC / PID · drive-by-wire (CAN)
- Compute
- Automotive-grade GPU/SoC edge compute · real-time ROS 2 middleware
- Operational design domain
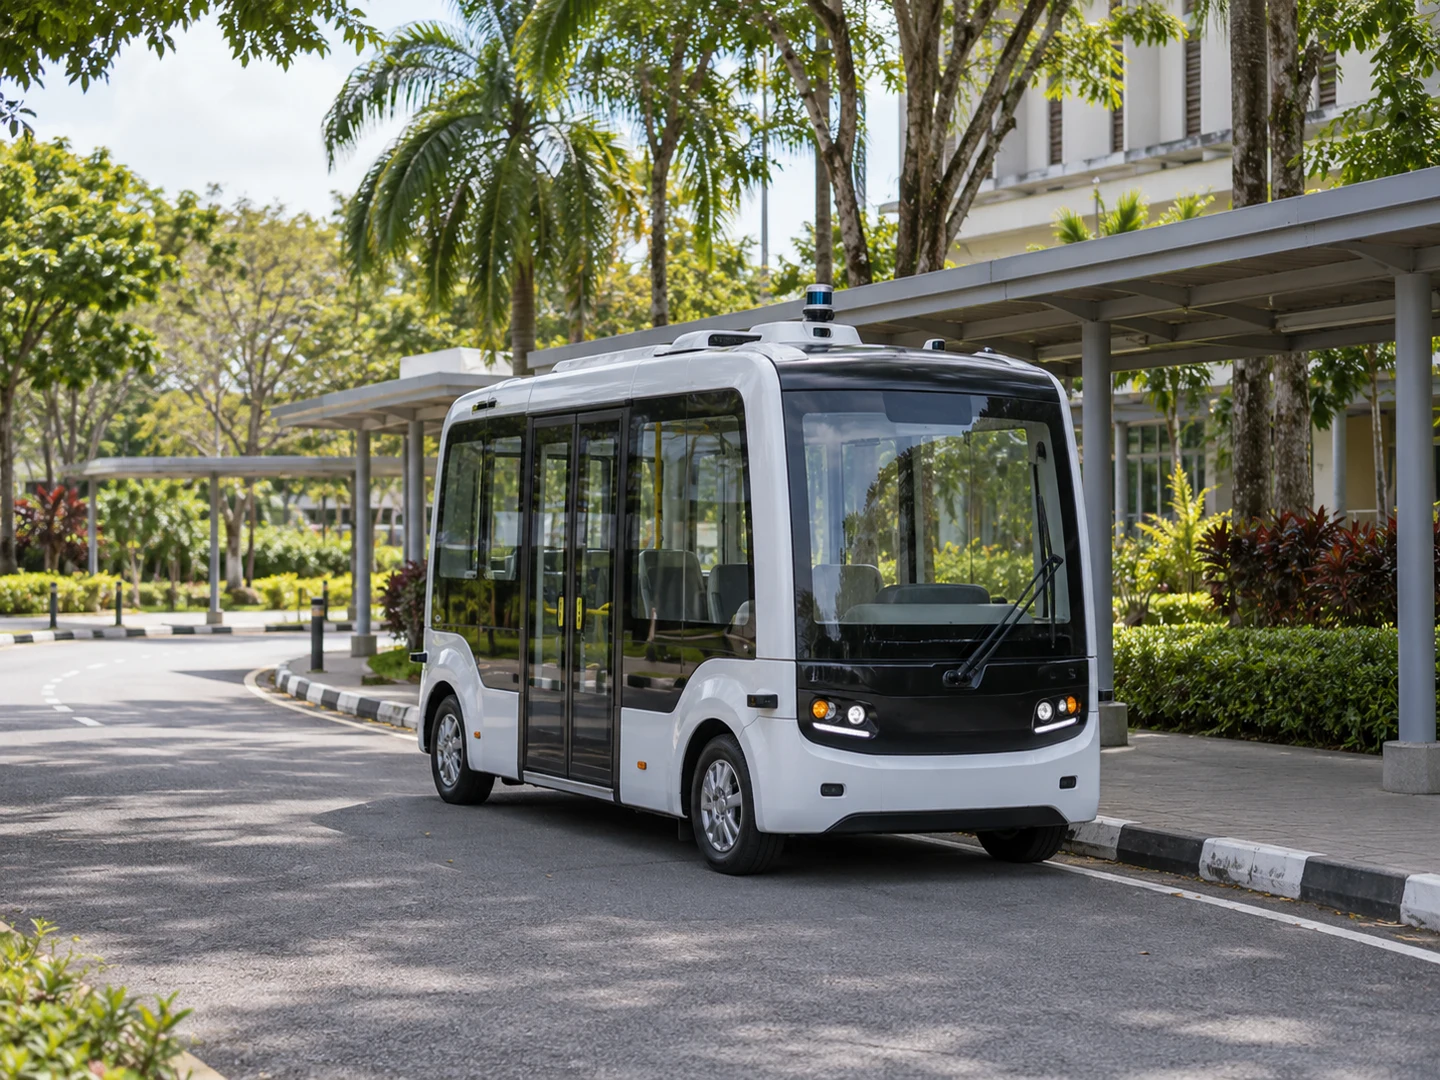
- Defined per deployment: shuttle routes, yards, ports, campuses, industrial sites
- Validation
- Scenario simulation · HIL/SIL · closed-course · supervised on-road
- Operations
- Teleoperation · fleet management · OTA updates · logging & replay