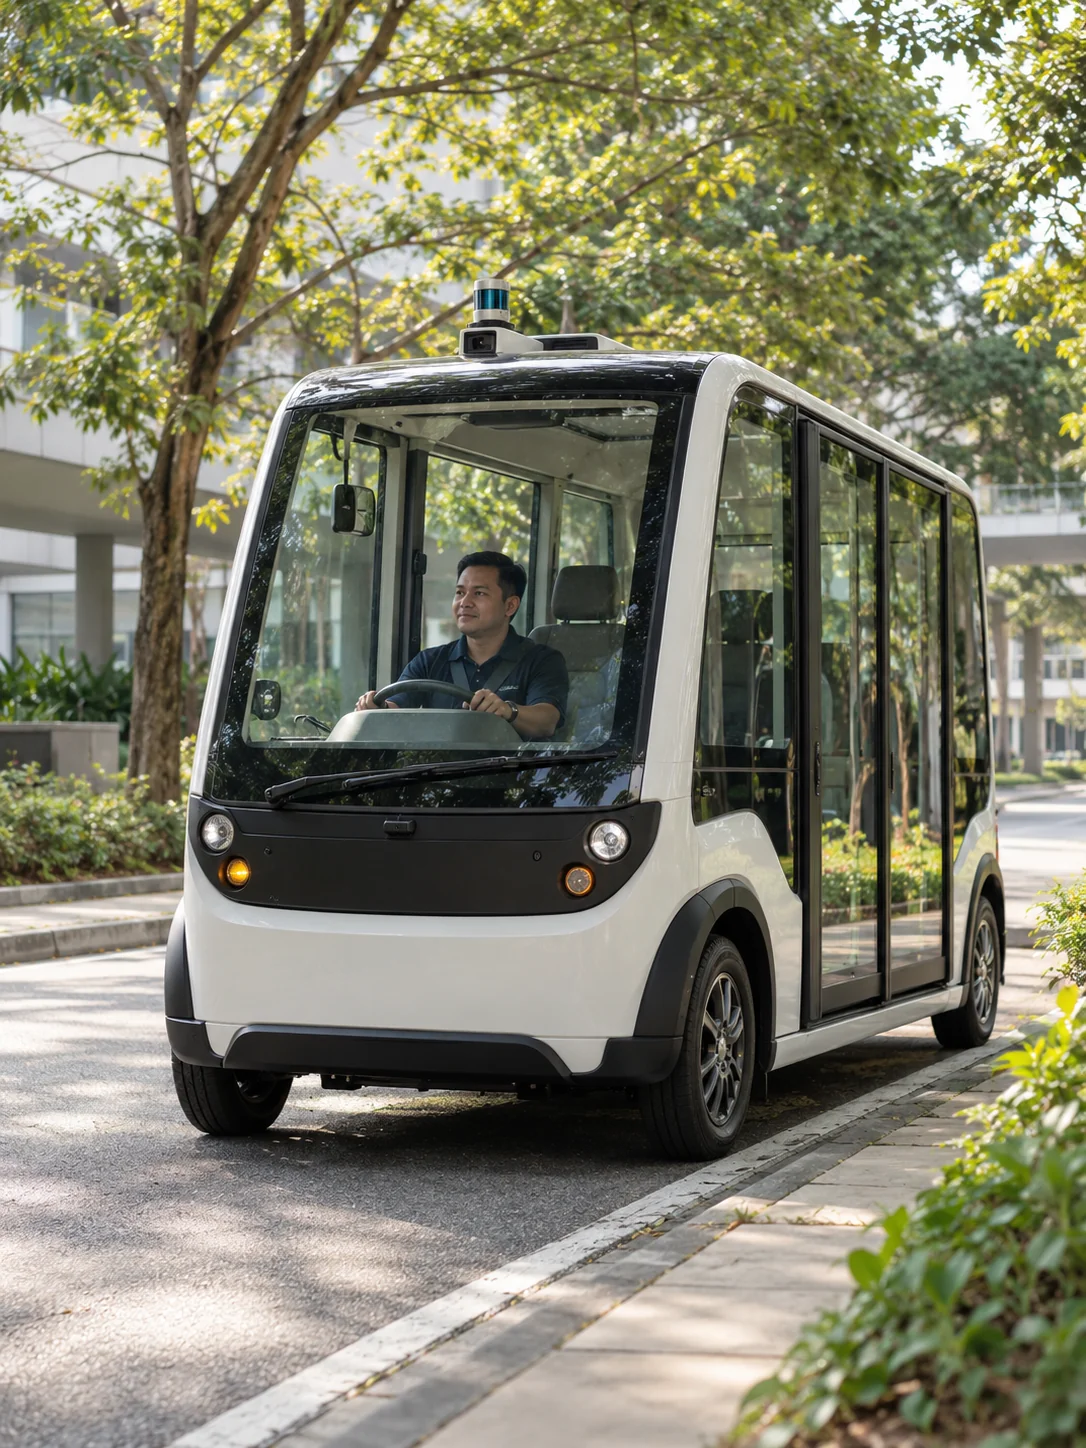
Autonomy, on real roads since 2016
In 2016 REKA built Malaysia’s first self-driving car, the first in Southeast Asia on public highways, and drove it from Melaka to Kuala Lumpur on the PLUS Highway, on our own hardware and autonomy stack. Today we start where autonomy already works and pays: yards, ports, farms and fixed routes.
Talk to our team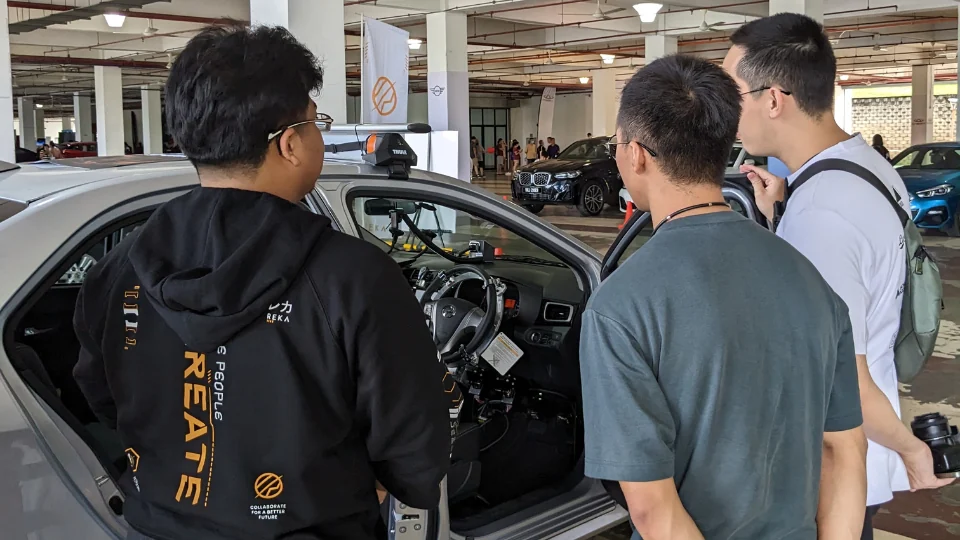
How we pursue autonomy
Not waiting for Level 5. We bound the world the machine operates in, prove it inside that boundary, then widen it.
Bound the domain
We start where autonomy already works and pays: yards, ports, farms, fixed routes.
Prove it inside
The machine earns trust inside that boundary, and hands over cleanly at its edge to a person who is always one step away.
Widen it
Each domain solved is a piece of infrastructure redesigned, and the start of the next one.
ReadoutNot waiting for Level 5. Hover or tap a ring to read it.
- Open stack
We build on Autoware, auditable and inspectable. Every layer of our stack can be opened, examined and replaced.
- Human in the loop
Teleoperation is a designed layer, not a failure mode.
- 2016
Malaysia’s first self-driving car on open roads, Melaka to Kuala Lumpur on the PLUS Highway
- 2017
Members of the public ride in it at the Malaysia Autoshow, with MARii
- 2021
We start building on the open-source Autoware stack
- 2023
An autonomous test bed at the Malaysia Autoshow, after test runs on a dedicated route in Cyberjaya
- 2024
REKA joins the Autoware Foundation
2016: Malaysia’s first self-driving car on open roads
Project CRETA: a retrofit kit for an ordinary car. MK I, a Proton Waja, saw the road through one webcam, with motors, servos and REKA’s own electronics, including its RIG board, on the wheel and pedals. By the end of 2016 it drove from Melaka to Kuala Lumpur with no one in the driver’s seat. MK II (mid-2017), a Proton Inspira courtesy of MIDA, added a puck LiDAR; MK III (late 2017), two Proton Perdanas from NanoMalaysia and MARA, carried LiDAR, side radars and three cameras each.
Read the case study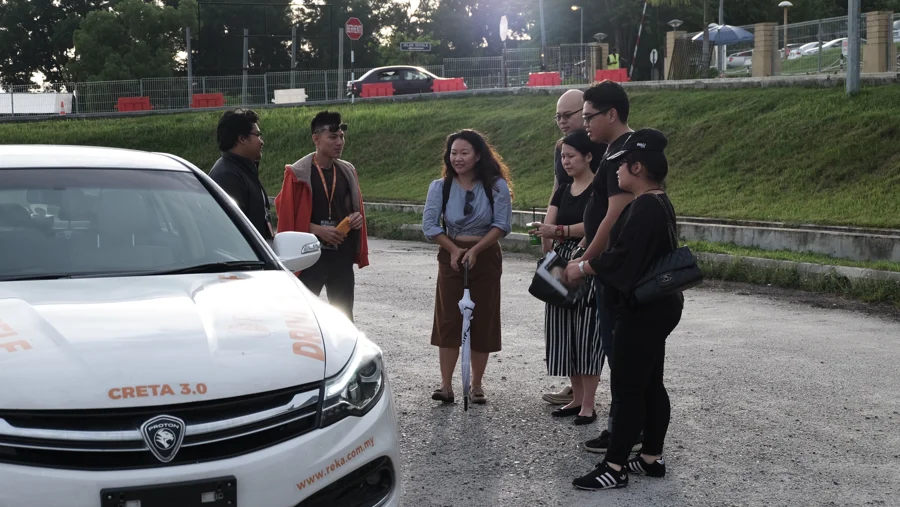 CRETA archive · Malaysia Autoshow 2017
The public takes a ride
At the Malaysia Autoshow 2017, with MARii, members of the public rode in our self-driving car. In 2023 we showed an autonomous test bed at the Malaysia Autoshow, after test runs on a dedicated route in Cyberjaya.
See the autonomy work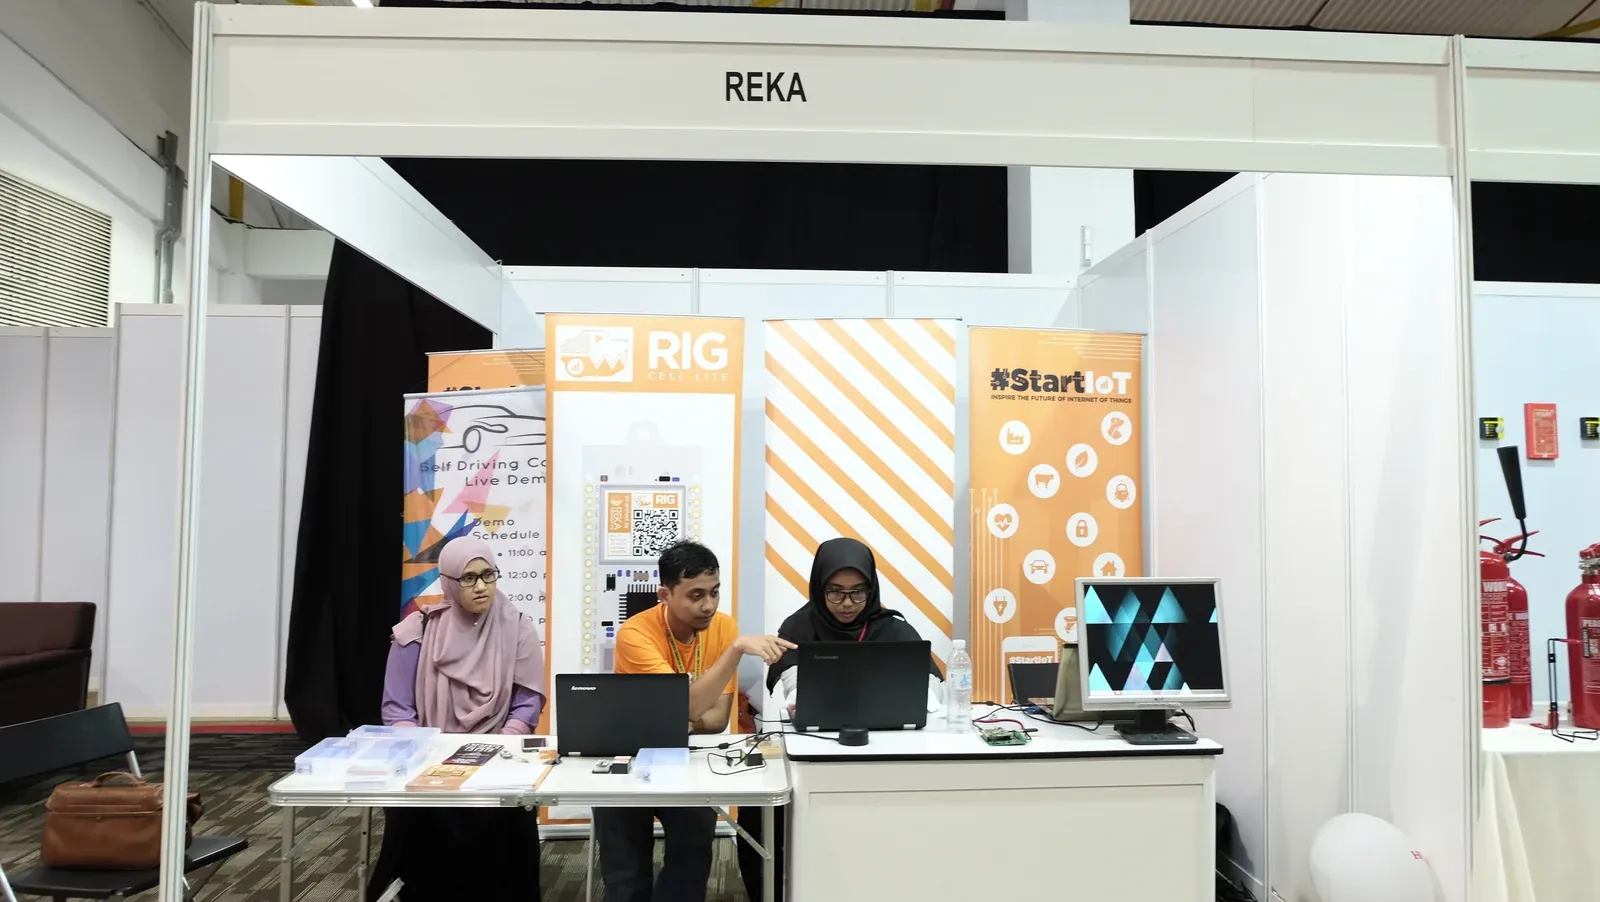
Every vehicle in view, and within reach
Motion is telematics and fleet management, built first for autonomous vehicles and remote control, carrying forward the work REKA began with its 2016 self-driving car. A closed pilot at AntaraX, run for you through REKA’s Intelligent Automation (Managed AI).
See it at antarax.ai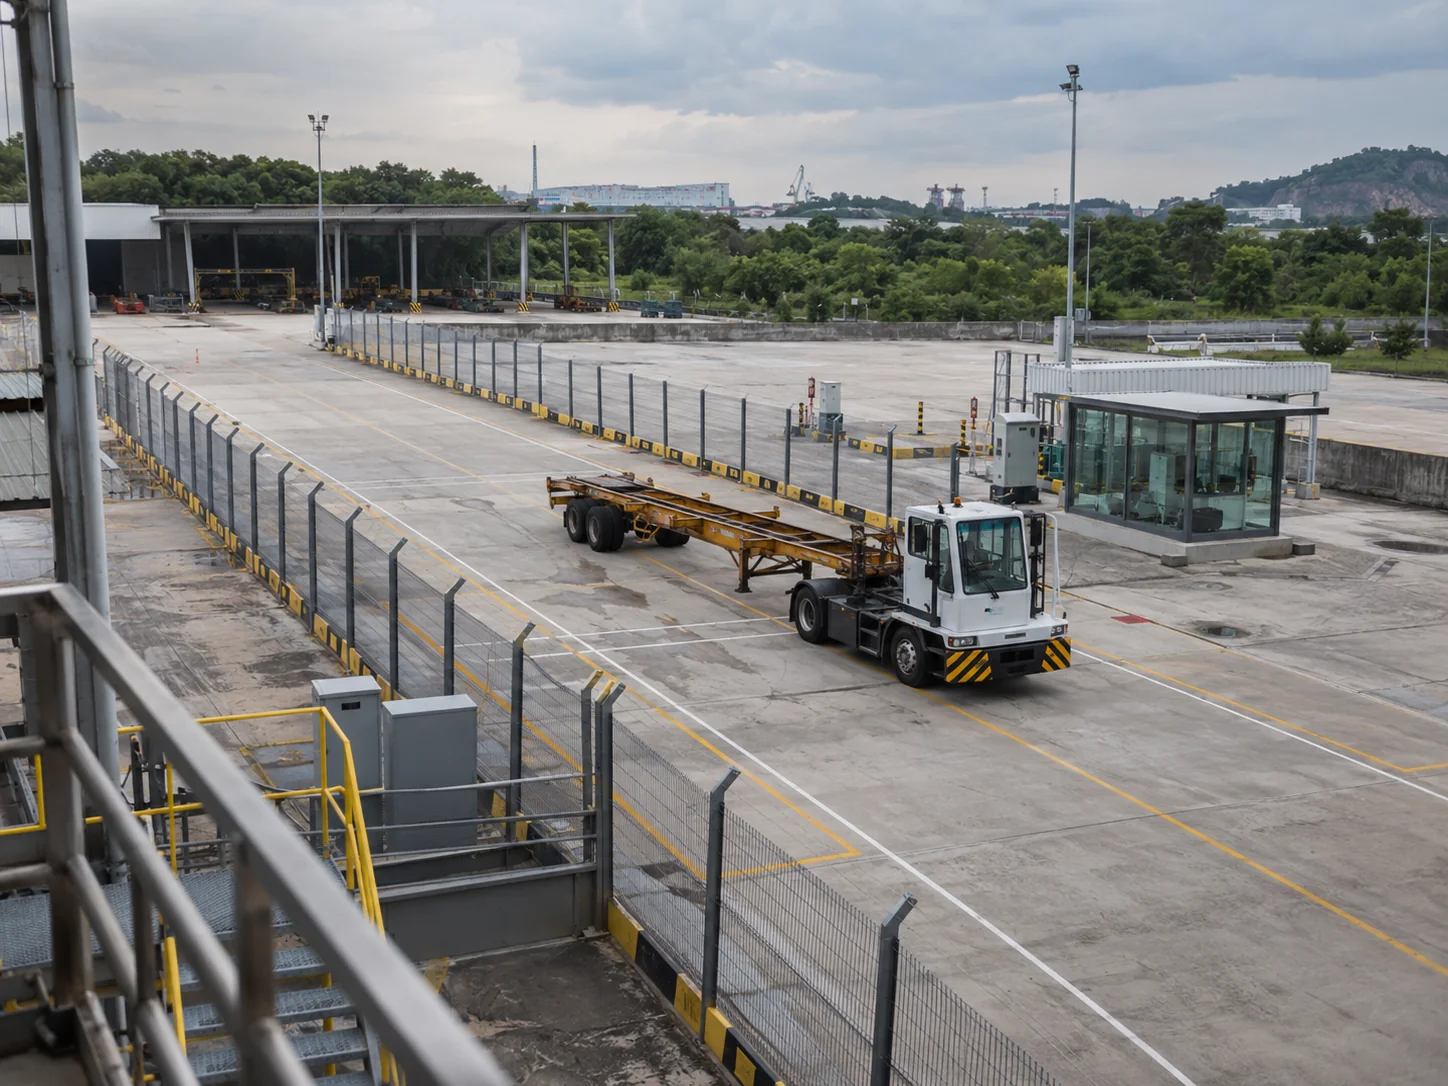
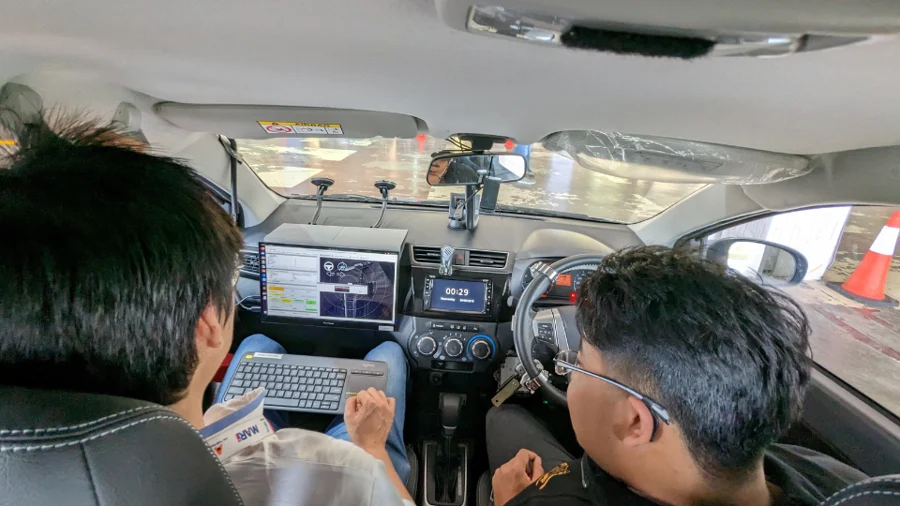 REKA archive · Malaysia Autoshow 2023
MARii
The Malaysia Automotive Robotics and IoT Institute is the main stakeholder in REKA’s autonomous vehicle project, from public rides at the Malaysia Autoshow 2017 to the test bed we showed together in 2023.
Read the case studyAutoware
As a member of the Autoware Foundation, we tune the open self-driving stack for the region’s roads, weather and traffic, and feed improvements back upstream.
See the autonomy workWhat the press wrote.
- Kereta Pandu Sendiri Jadi Tumpuan Pada NICE 2017Astro Awani2017
- Want to Ride in a Proton Perdana that’s been Retrofitted into an Autonomous Car?Autoshow.com.my2017
- Malaysian Startup REKA Showcases Self-Driving Car Technology at KLIASMotion Digest2017
- M’sians Who Made Their Own ‘Tesla’ Want Local Opportunities Despite Getting Foreign OffersSAYS2017
- Kereta Tanpa PemanduHarian Metro2017
- What Would Cars Of The Future Look Like?Lowyat.net2017
Put autonomy to work.
Thank you, we’ve got it.
REKA’s autonomy team reads every message and aims to reply within one business day, from [email protected].
We’ll reply to .